ROBOTICS & ELECTROMECHANICAL DESIGN
Magnetic Pick-and-Place Robot
Course: Engineering Design Experience · Lewisburg, PA
September 2025 – December 2025
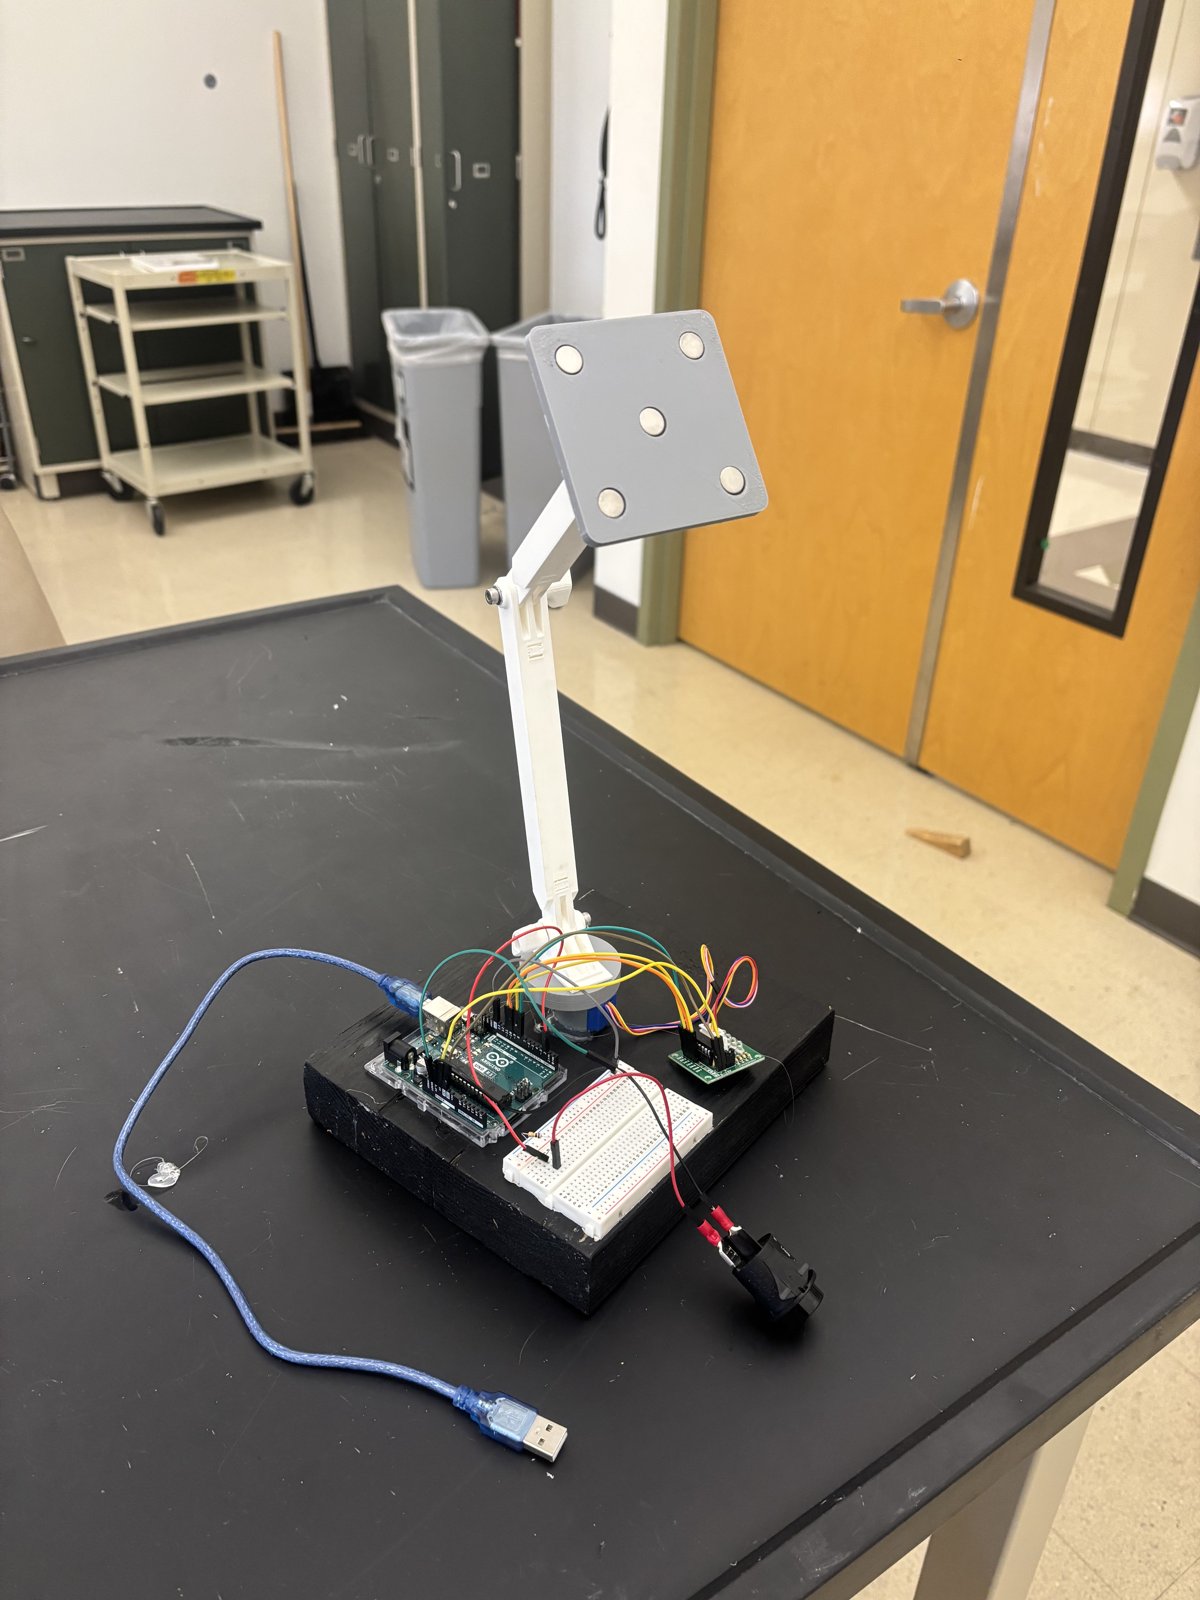
I designed, modeled, and assembled a magnetic robotic arm for my Engineering Design Experience course. The 3D-printed, Arduino-powered system was built to explore automated quality control and component sorting in manufacturing workflows.
Project overview
For my Engineering Design Experience course, I developed a magnetic robotic arm through design, modeling, and assembly. Combining 3D-printed hardware with Arduino control, the project explored automated quality control and component sorting in manufacturing workflows.
Engineering details
- Hardware: 3D-printed robotic arm with magnetic pickup
- Control platform: Arduino for pick-and-place automation